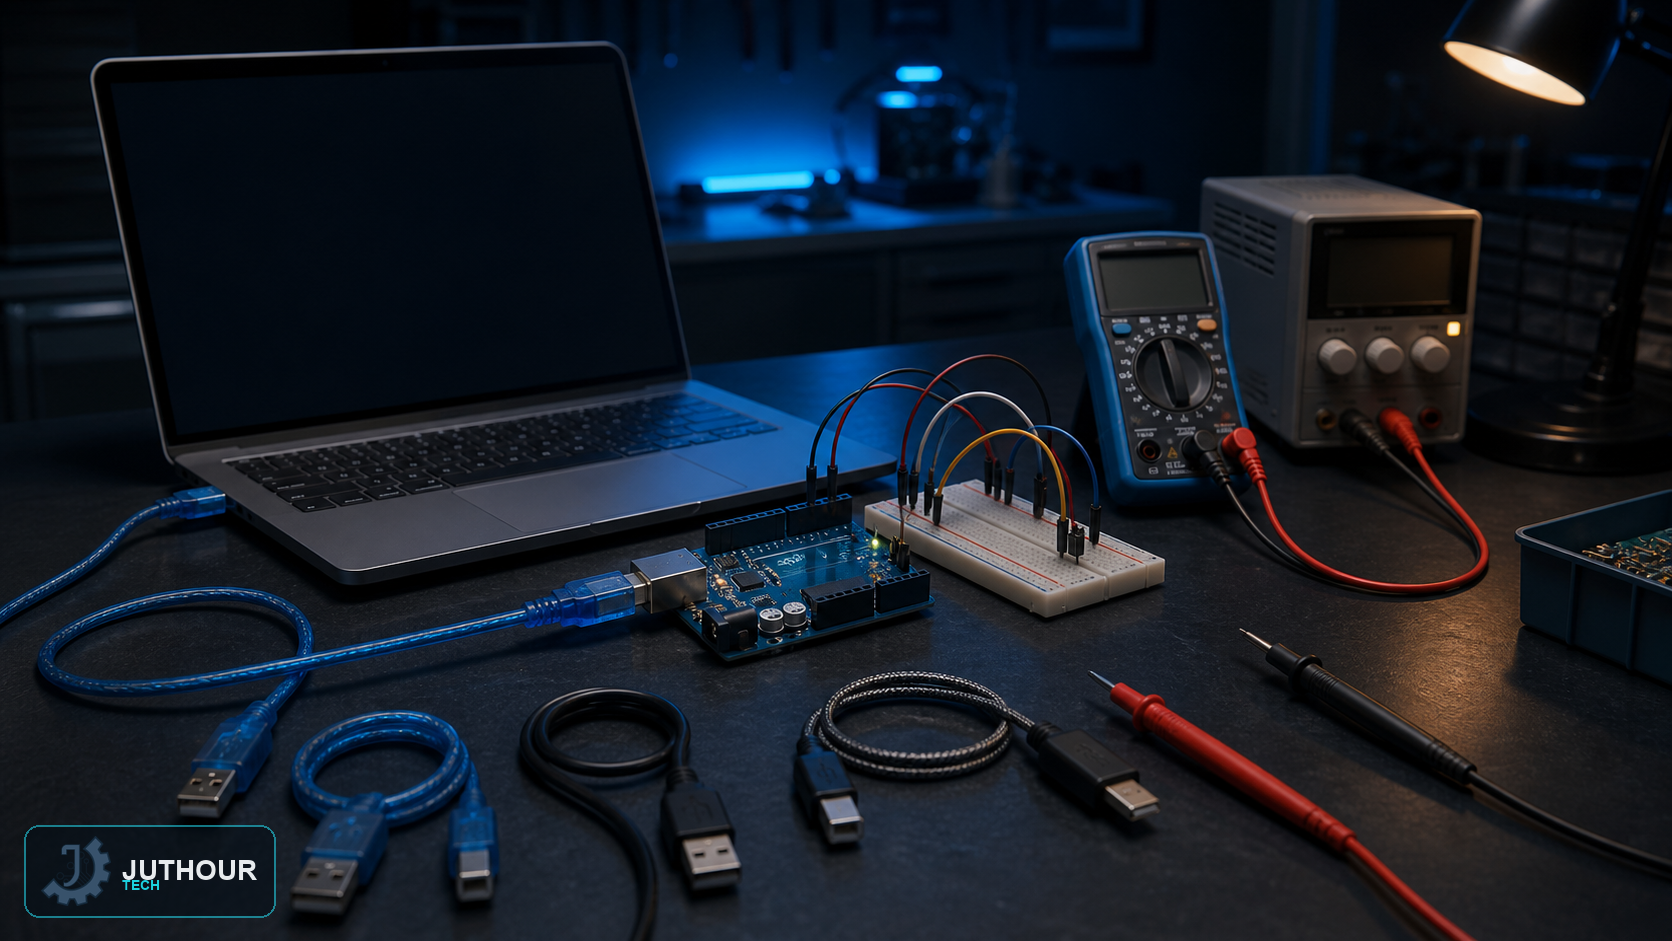
Part one covers the faults that occur before code runs: USB cables, board and port selection, drivers, upload conflicts and external power.
 JUTHOURTECH
Part one covers the faults that occur before code runs: USB cables, board and port selection, drivers, upload conflicts and external power.
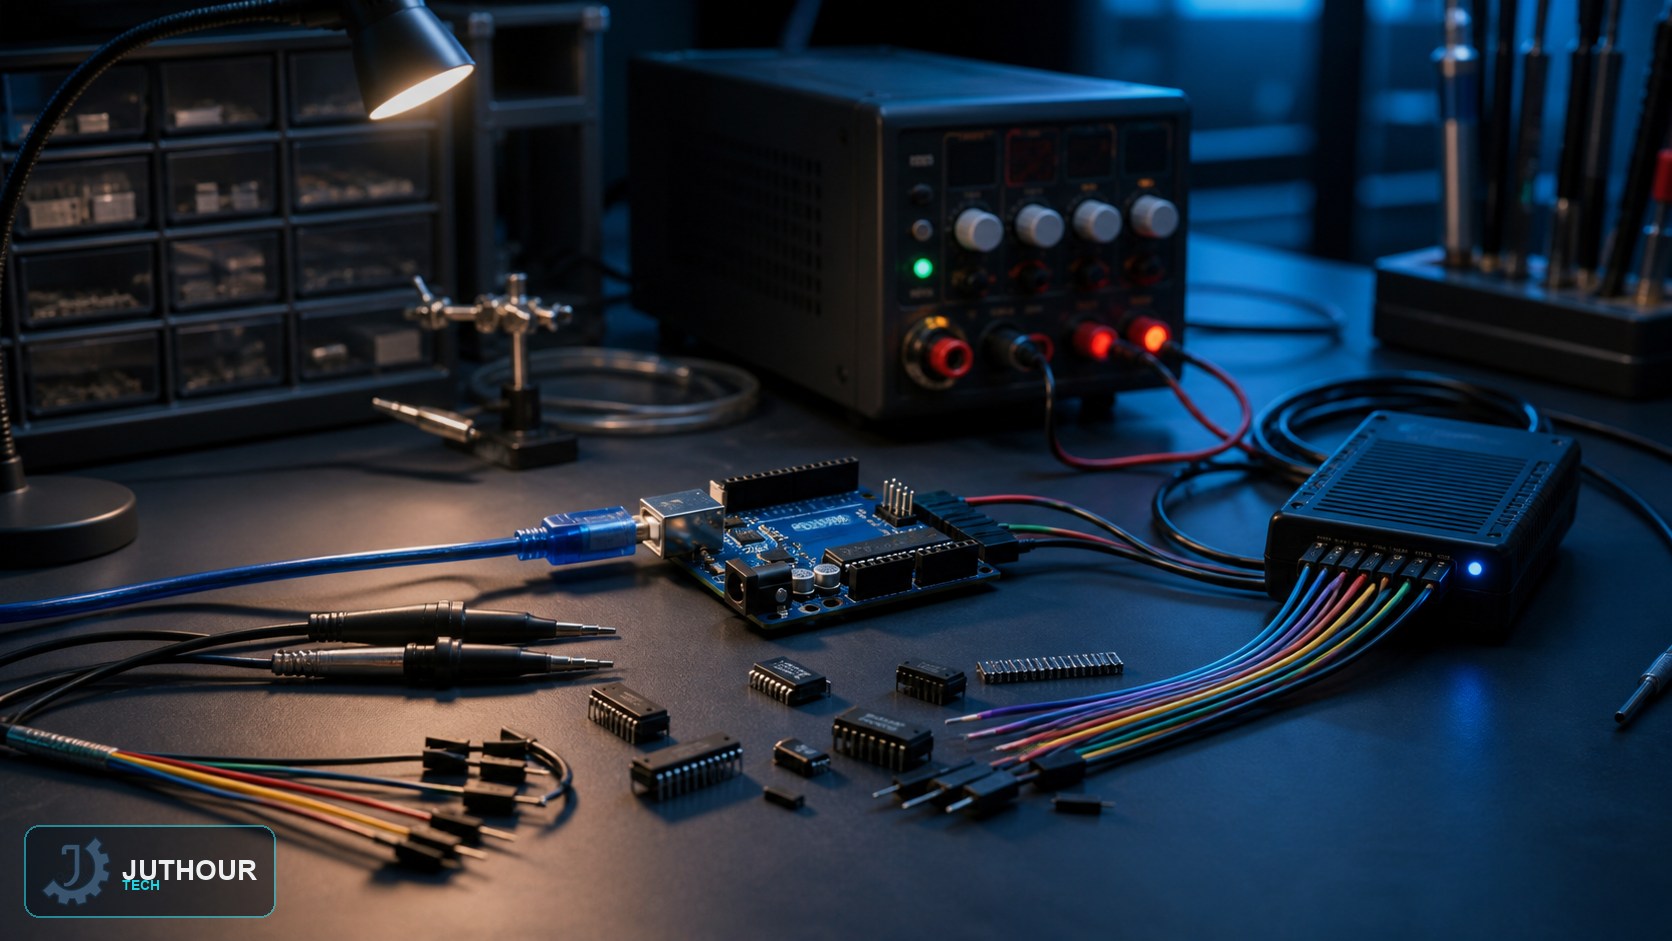
Part two focuses on problems after compilation: runtime logic, SRAM, library selection, serial-port conflicts and power integrity.
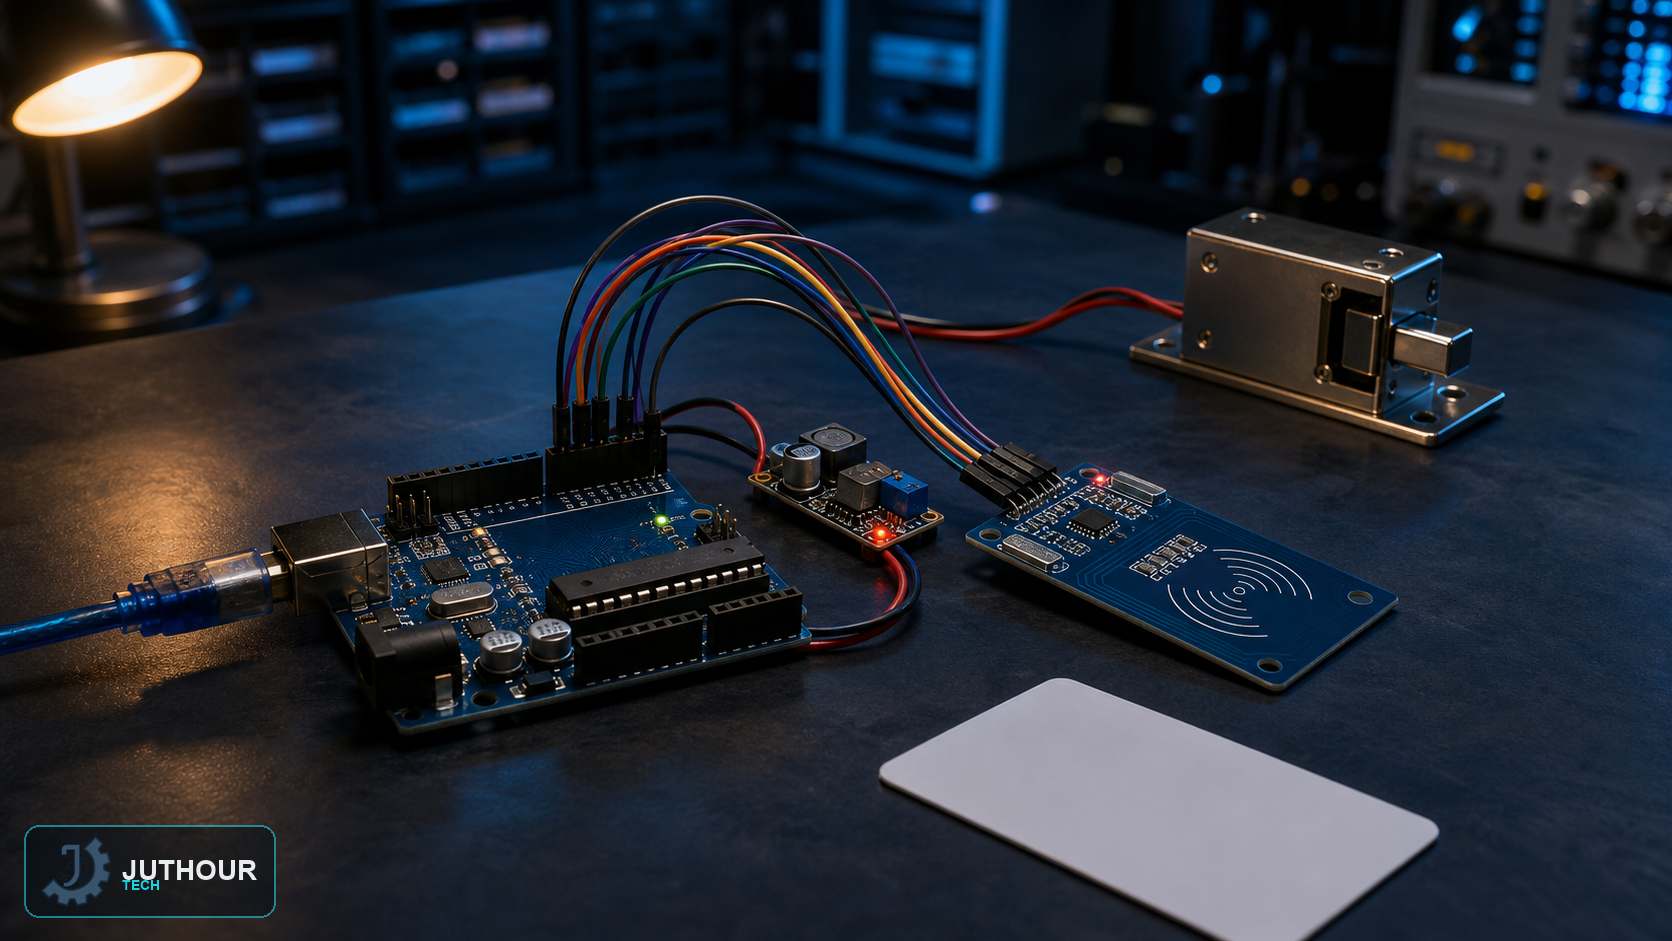
A practical MFRC522 and Arduino access-control prototype with correct wiring, power separation and a safe path from LEDs to a real lock actuator.
Build a local ESP32 servo interface with native fetch, debounced requests, server-side angle validation, safe limits, and remote-access guidance.