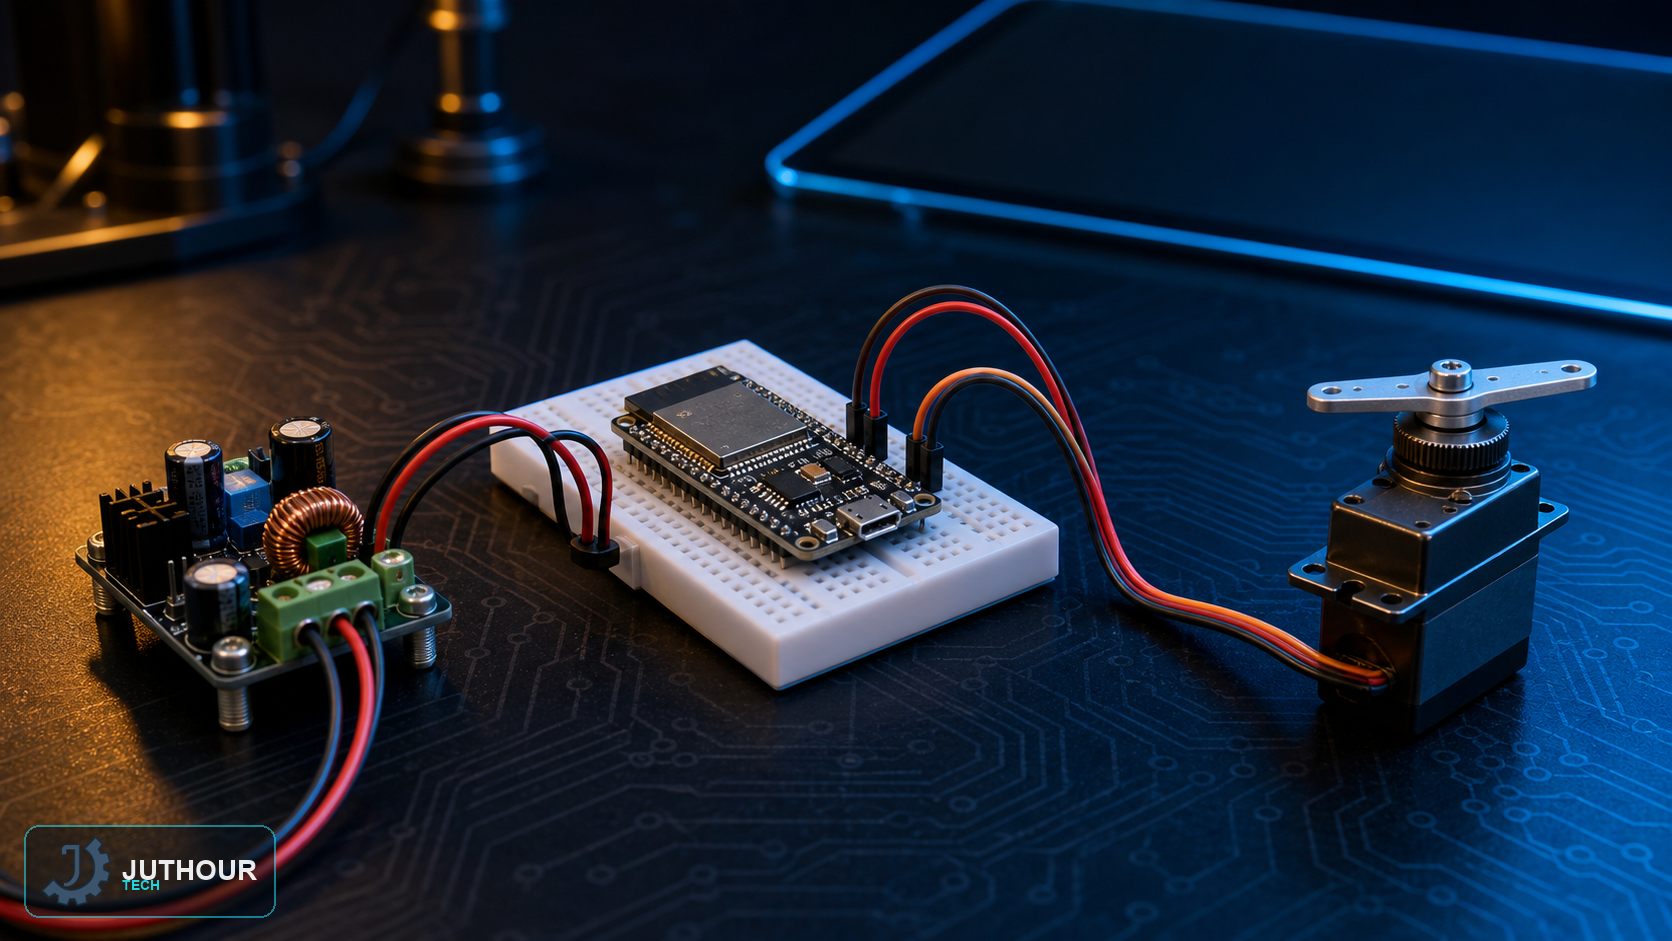
Start reliable ESP32 servo control with an external 5 V supply, board-specific GPIO selection, pulse calibration, and mechanical safety.
 JUTHOURTECH
Start reliable ESP32 servo control with an external 5 V supply, board-specific GPIO selection, pulse calibration, and mechanical safety.
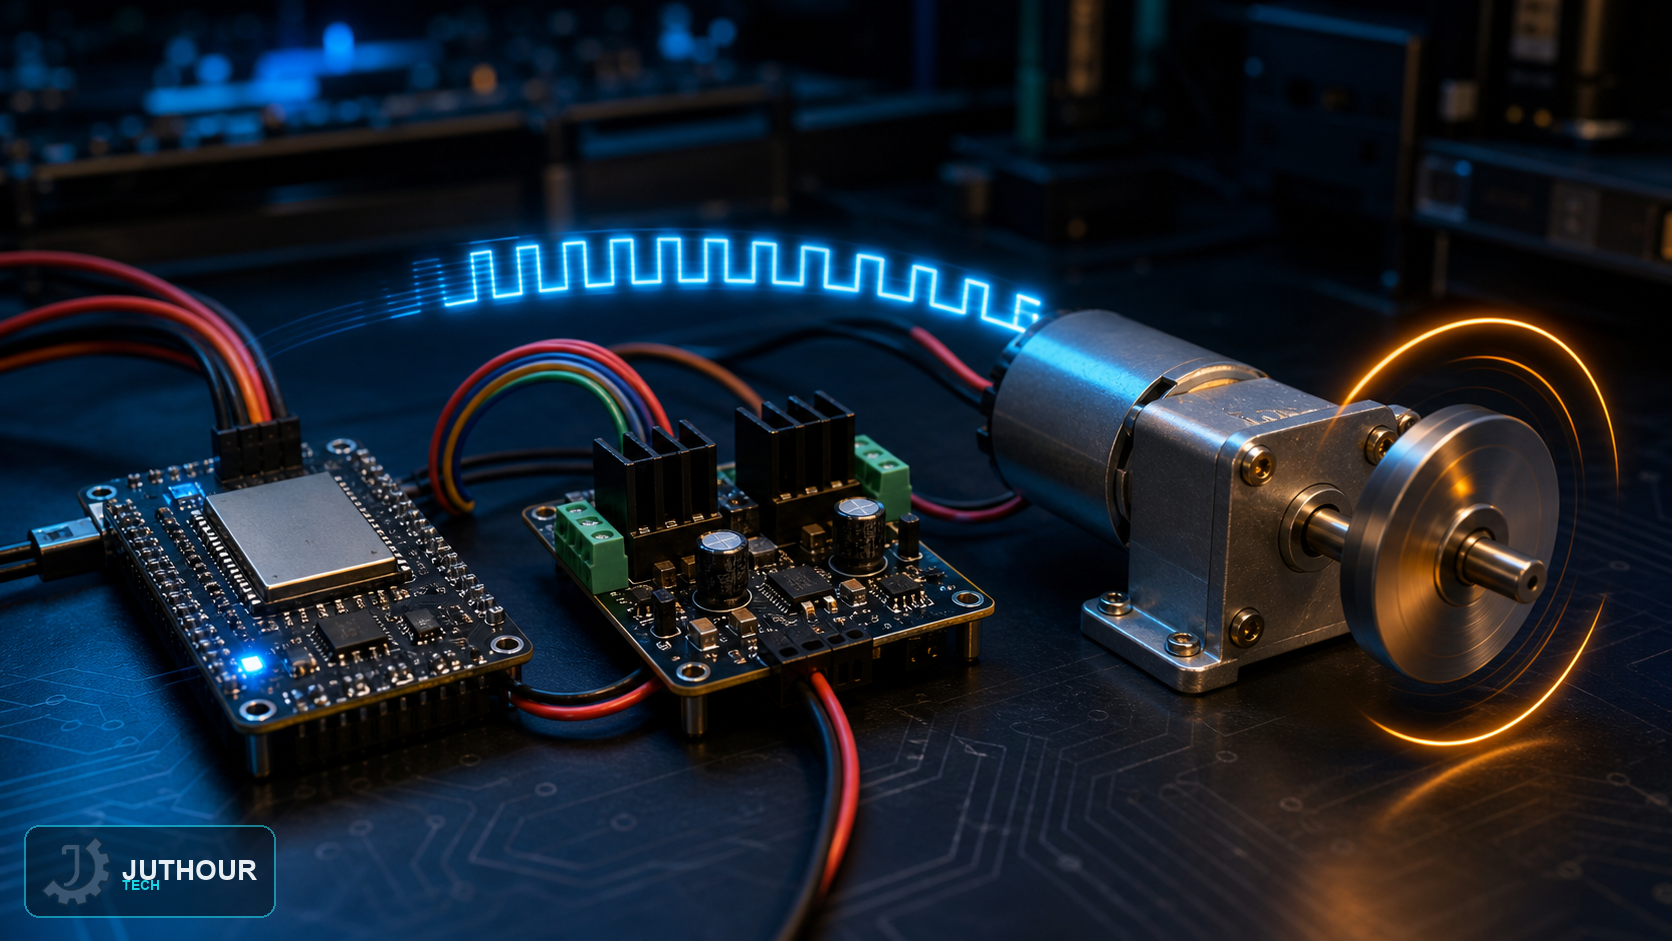
Control a DC motor with ESP32 using the current LEDC API, correct H-bridge wiring, L298N loss guidance, and safer driver selection.
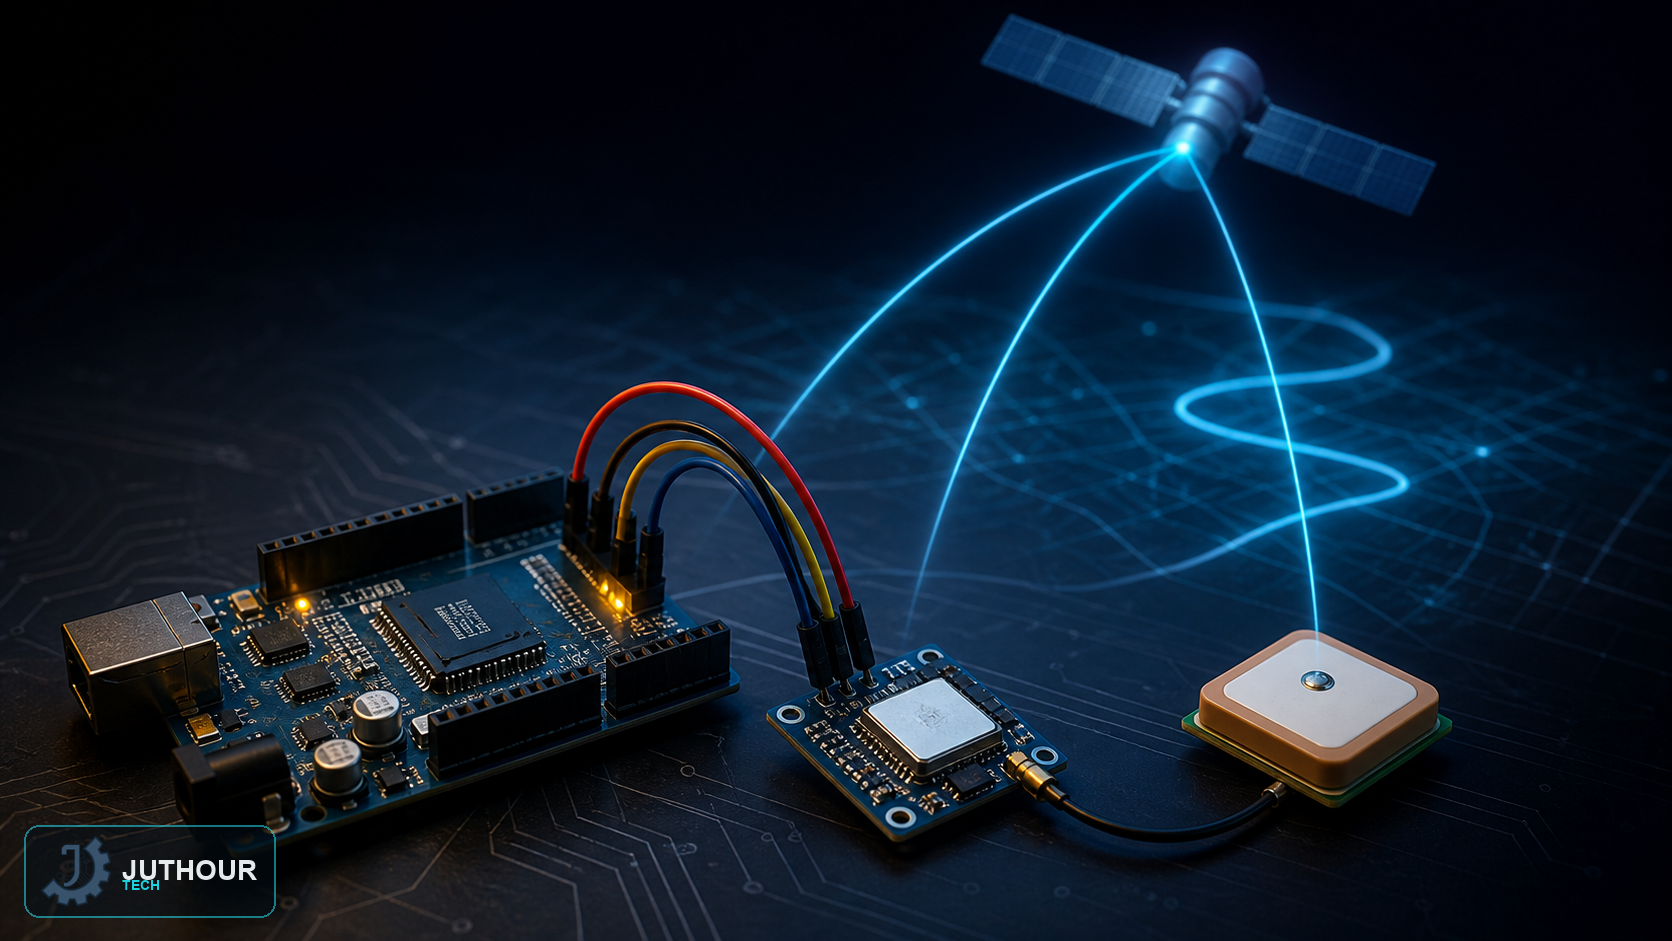
Understand NEO-6M channels, nominal accuracy, 5 Hz updates, four-satellite 3D fixes, board-specific power, antennas, and UART data.
Explaining how the three-axis MEMS-based ADXL335 sensor works and wiring it to Arduino's analog pins to measure tilt and acceleration.