Part two focuses on problems after compilation: runtime logic, SRAM, library selection, serial-port conflicts and power integrity.
 JUTHOURTECH
Part two focuses on problems after compilation: runtime logic, SRAM, library selection, serial-port conflicts and power integrity.
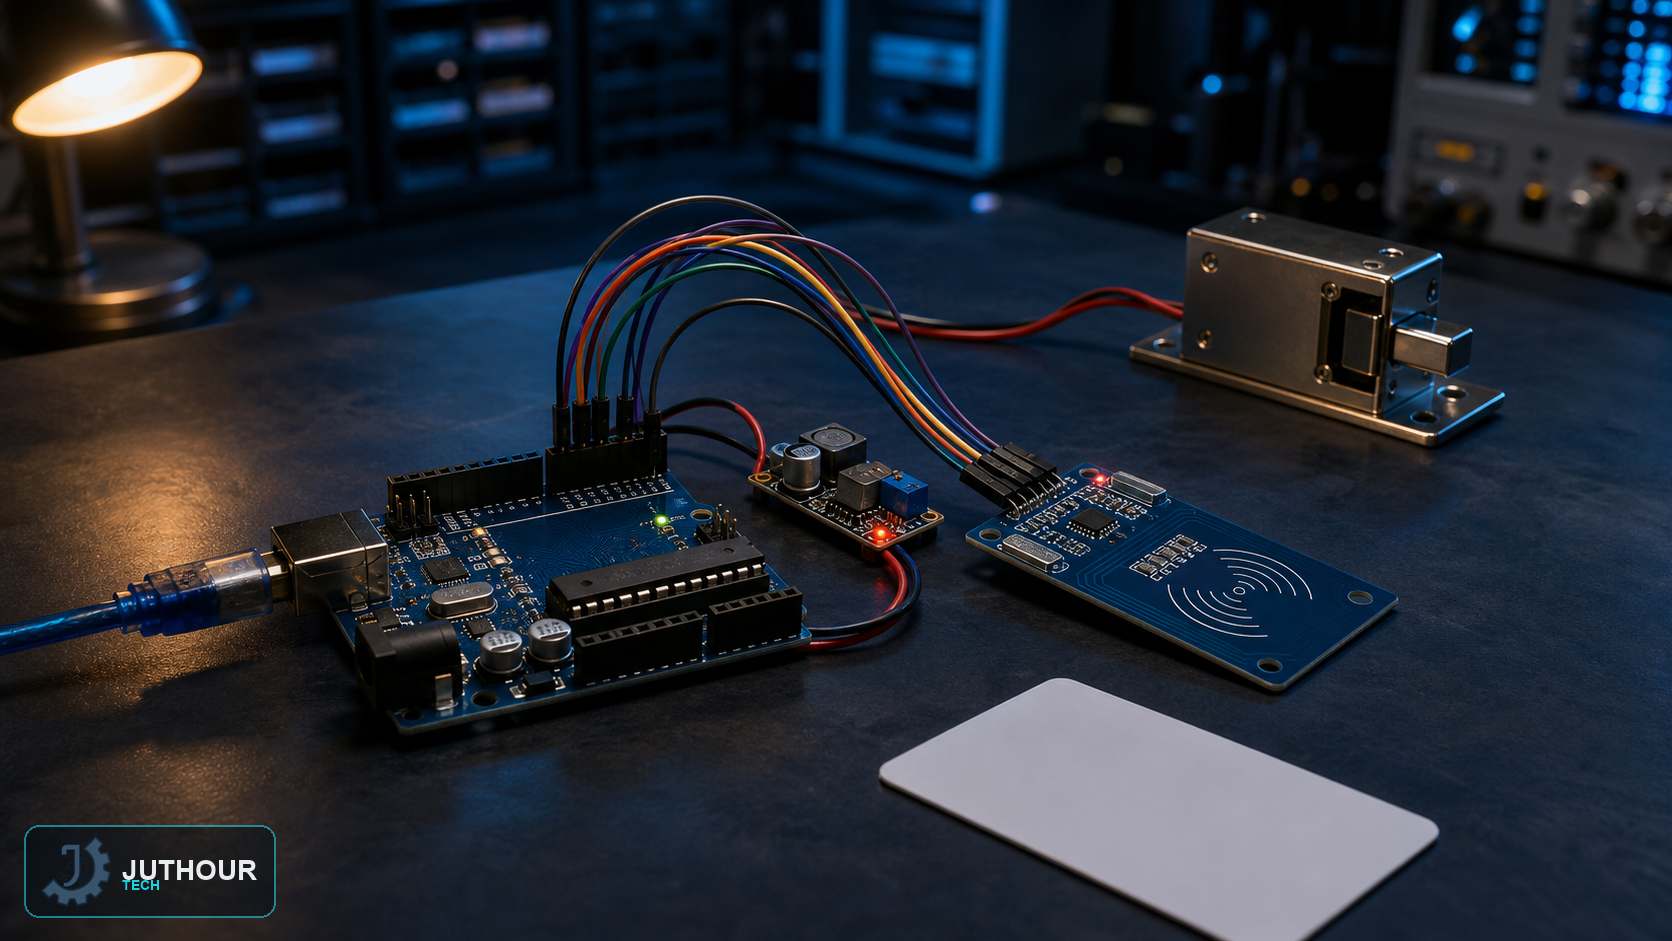
A practical MFRC522 and Arduino access-control prototype with correct wiring, power separation and a safe path from LEDs to a real lock actuator.
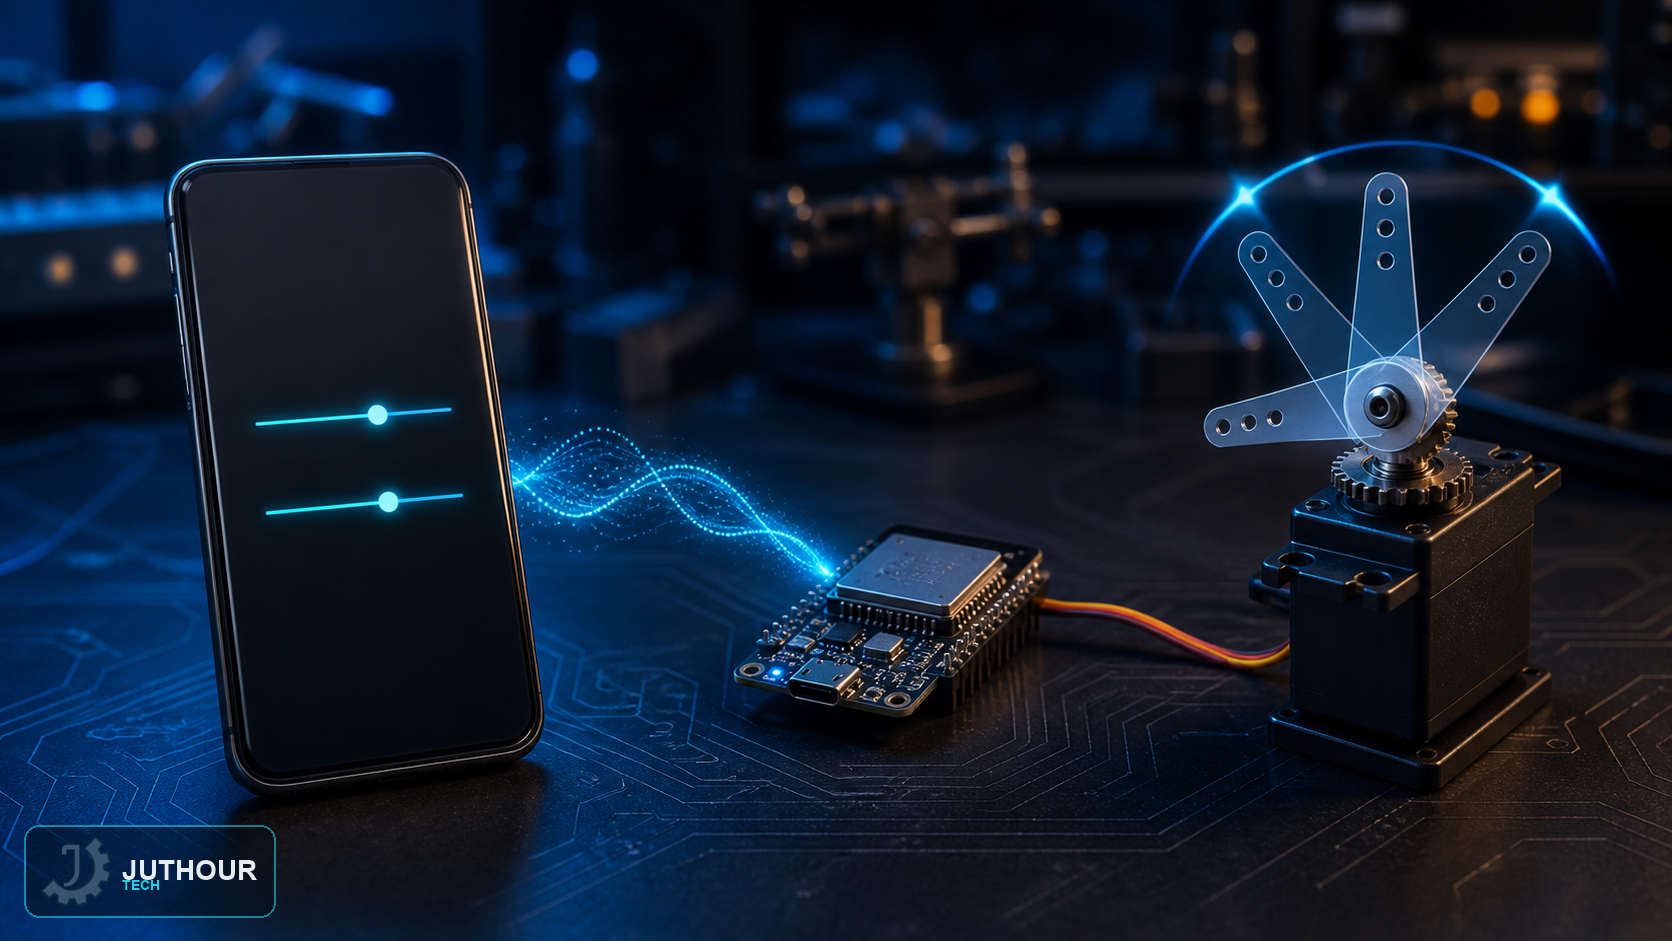
Build a local ESP32 servo interface with native fetch, debounced requests, server-side angle validation, safe limits, and remote-access guidance.
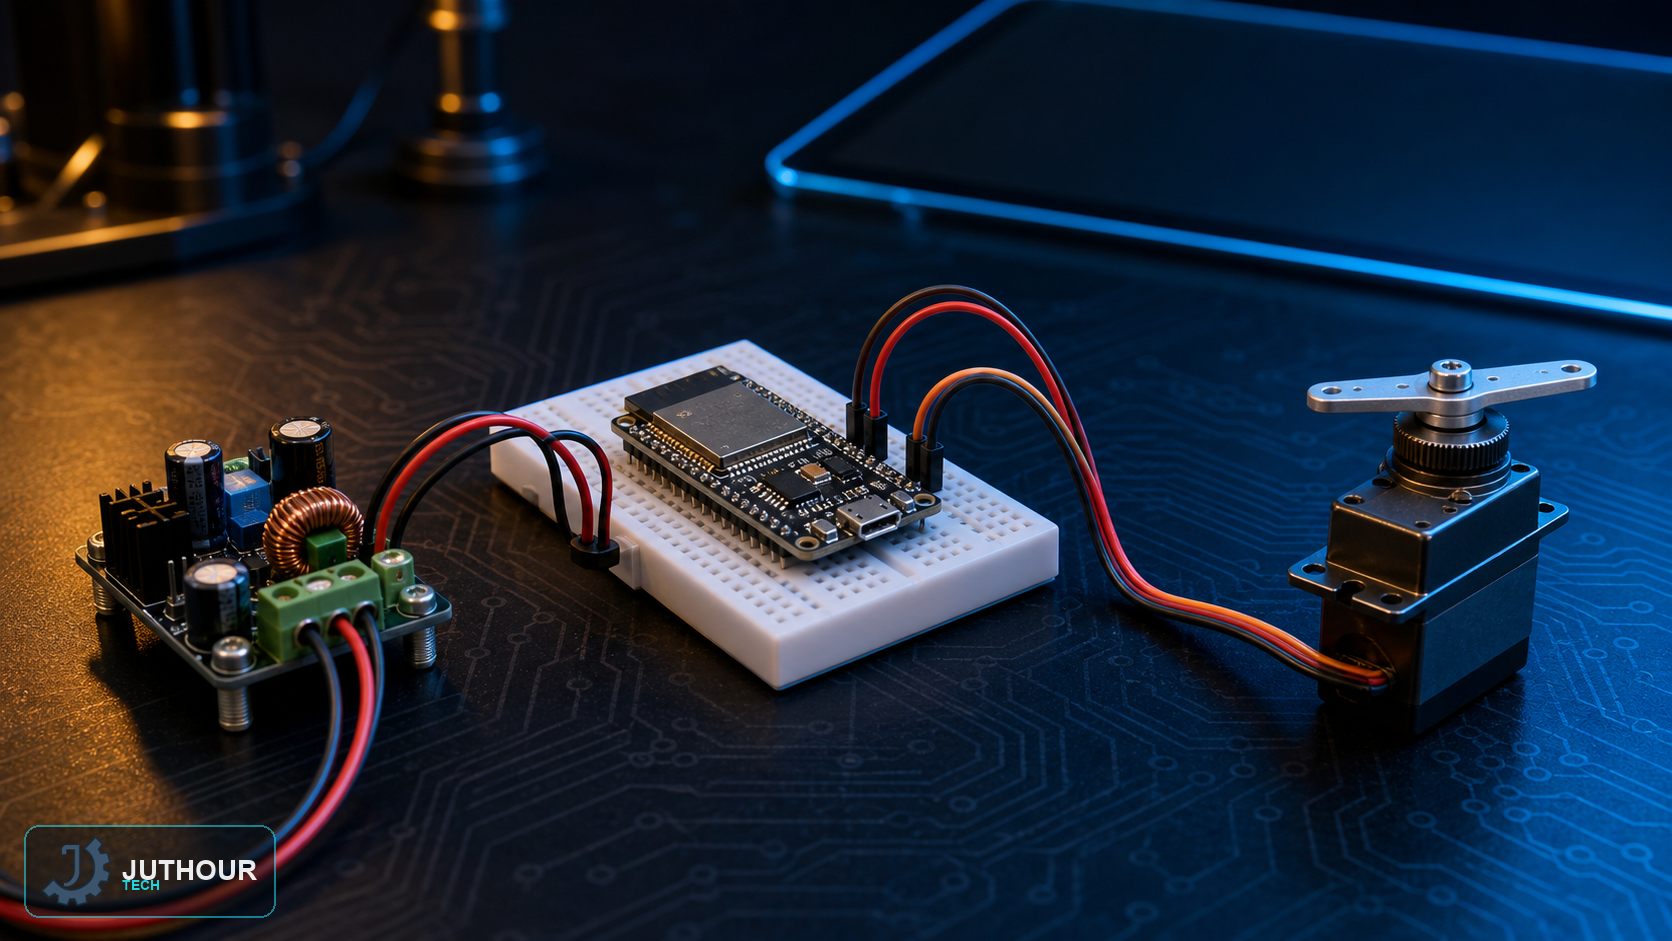
Start reliable ESP32 servo control with an external 5 V supply, board-specific GPIO selection, pulse calibration, and mechanical safety.