Control a DC motor with ESP32 using the current LEDC API, correct H-bridge wiring, L298N loss guidance, and safer driver selection.
 JUTHOURTECH
Control a DC motor with ESP32 using the current LEDC API, correct H-bridge wiring, L298N loss guidance, and safer driver selection.
Understand NEO-6M channels, nominal accuracy, 5 Hz updates, four-satellite 3D fixes, board-specific power, antennas, and UART data.
Explaining how the three-axis MEMS-based ADXL335 sensor works and wiring it to Arduino's analog pins to measure tilt and acceleration.
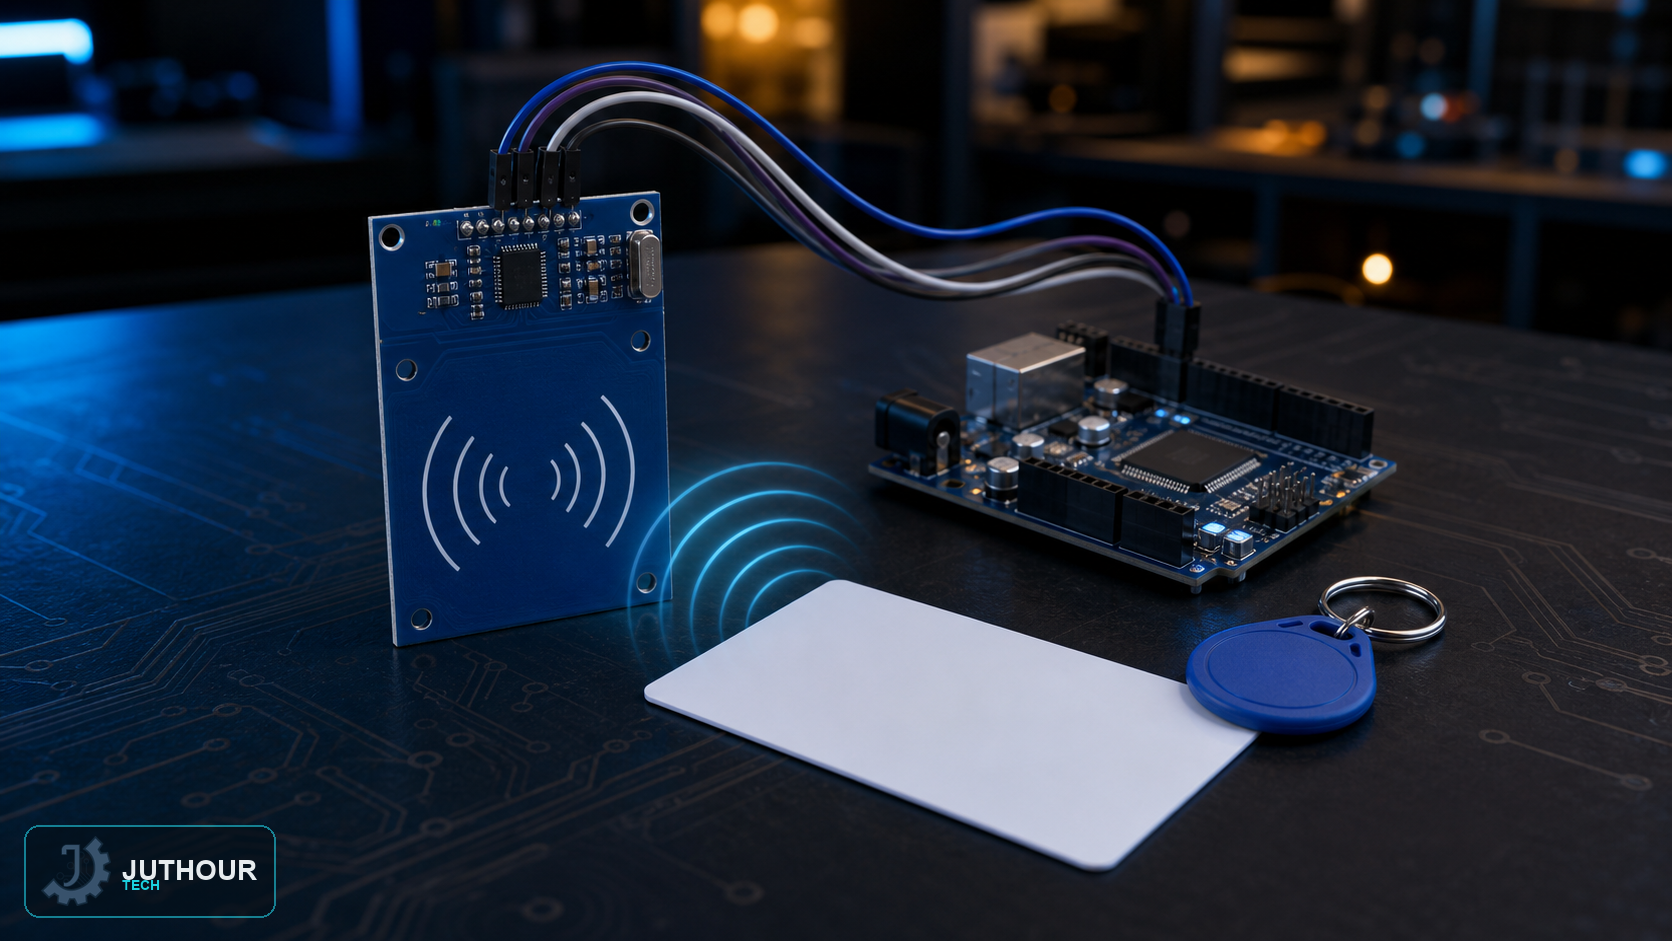
Explaining how RFID works and the MFRC522 reader module, which runs on 3.3V logic over SPI, plus reading a card's ID from Arduino.