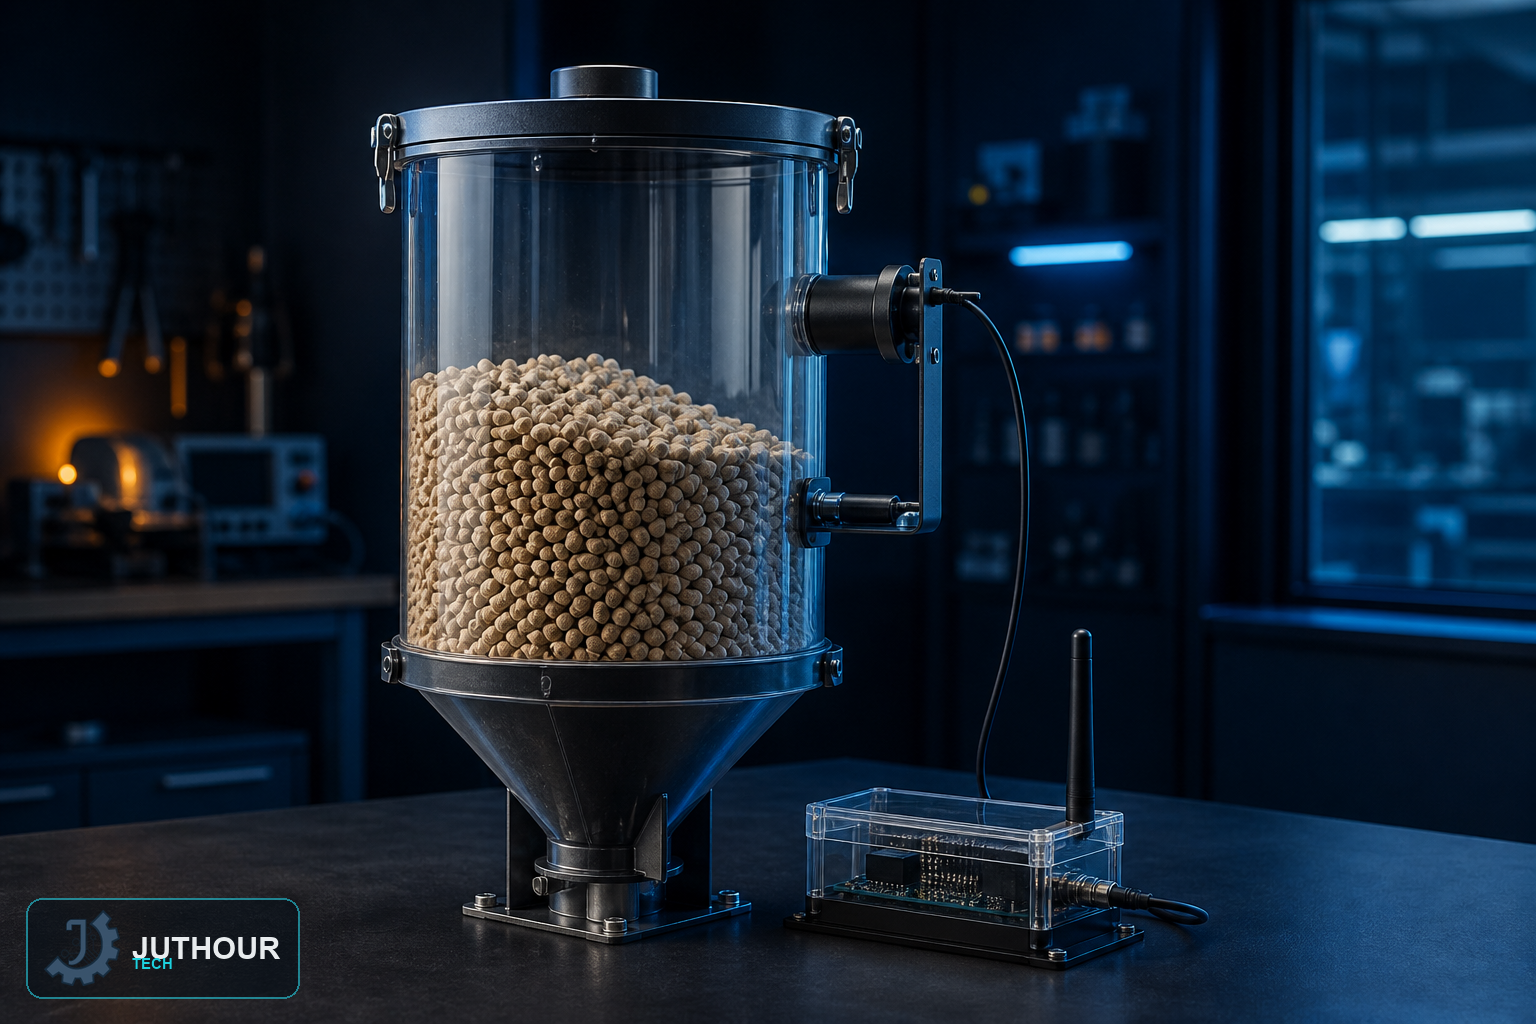
Estimate level on a sealed feed-bin model with non-contact sensing while studying uneven surfaces, dust, blind zones, condensation, and data loss.
 JUTHOURTECH
Estimate level on a sealed feed-bin model with non-contact sensing while studying uneven surfaces, dust, blind zones, condensation, and data loss.