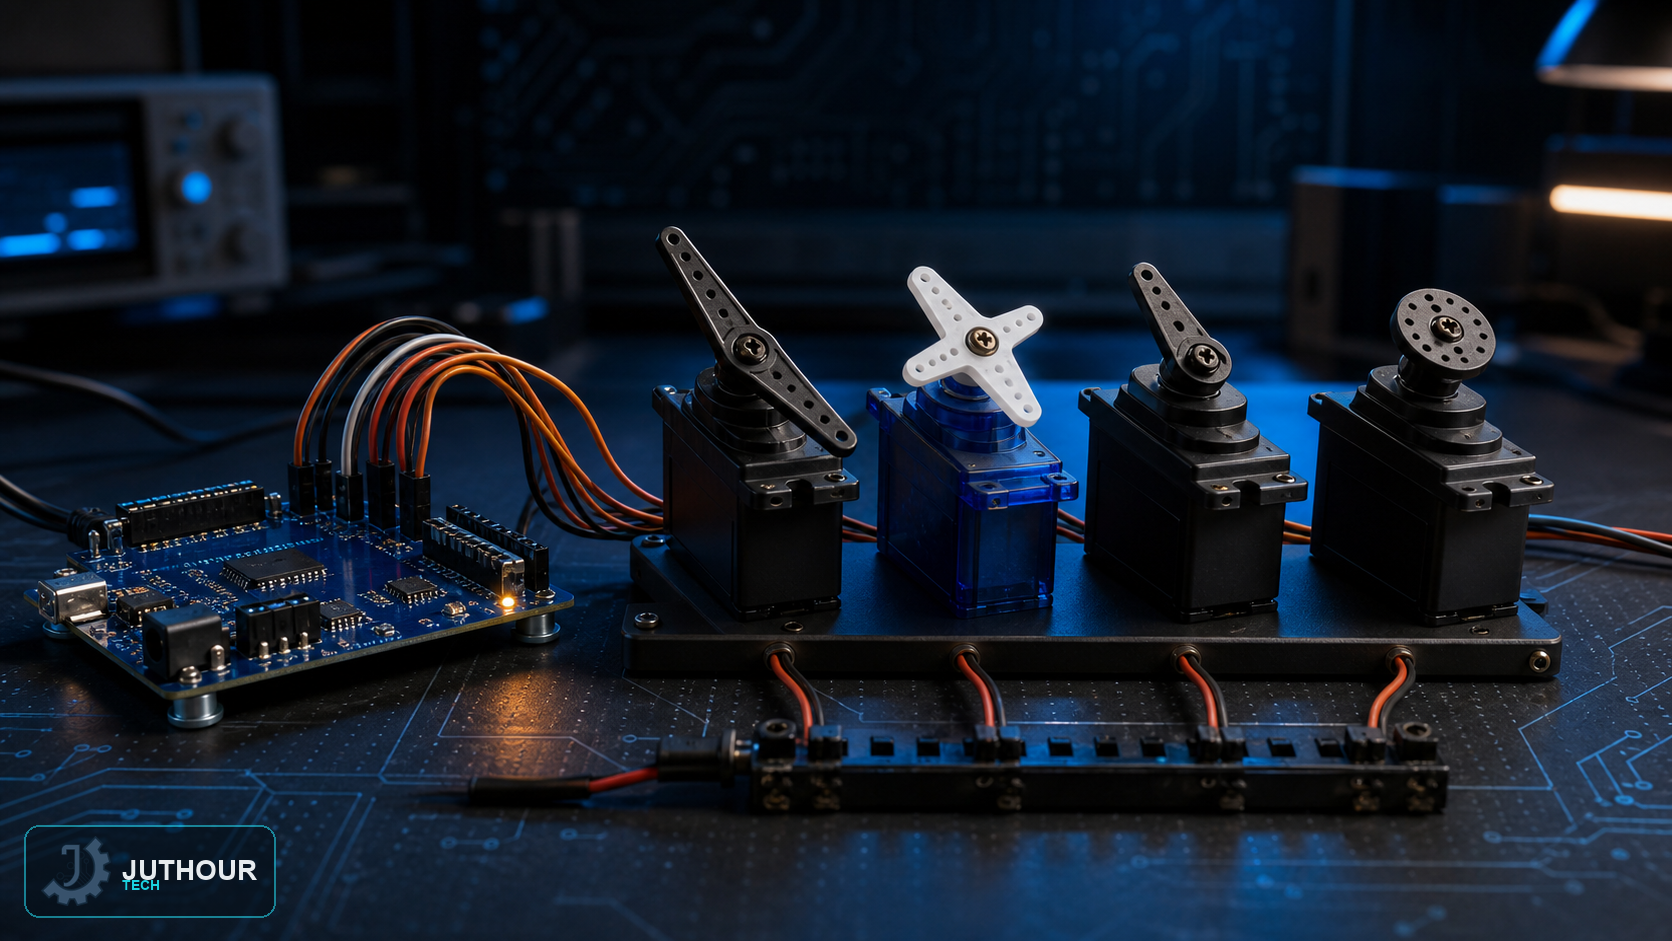
Wire four servo motors to an external power supply and control them together in full synchronization via the Servo library, with a safety note on power supply.
 JUTHOURTECH
Wire four servo motors to an external power supply and control them together in full synchronization via the Servo library, with a safety note on power supply.