Control a DC motor with ESP32 using the current LEDC API, correct H-bridge wiring, L298N loss guidance, and safer driver selection.
 JUTHOURTECH
Control a DC motor with ESP32 using the current LEDC API, correct H-bridge wiring, L298N loss guidance, and safer driver selection.
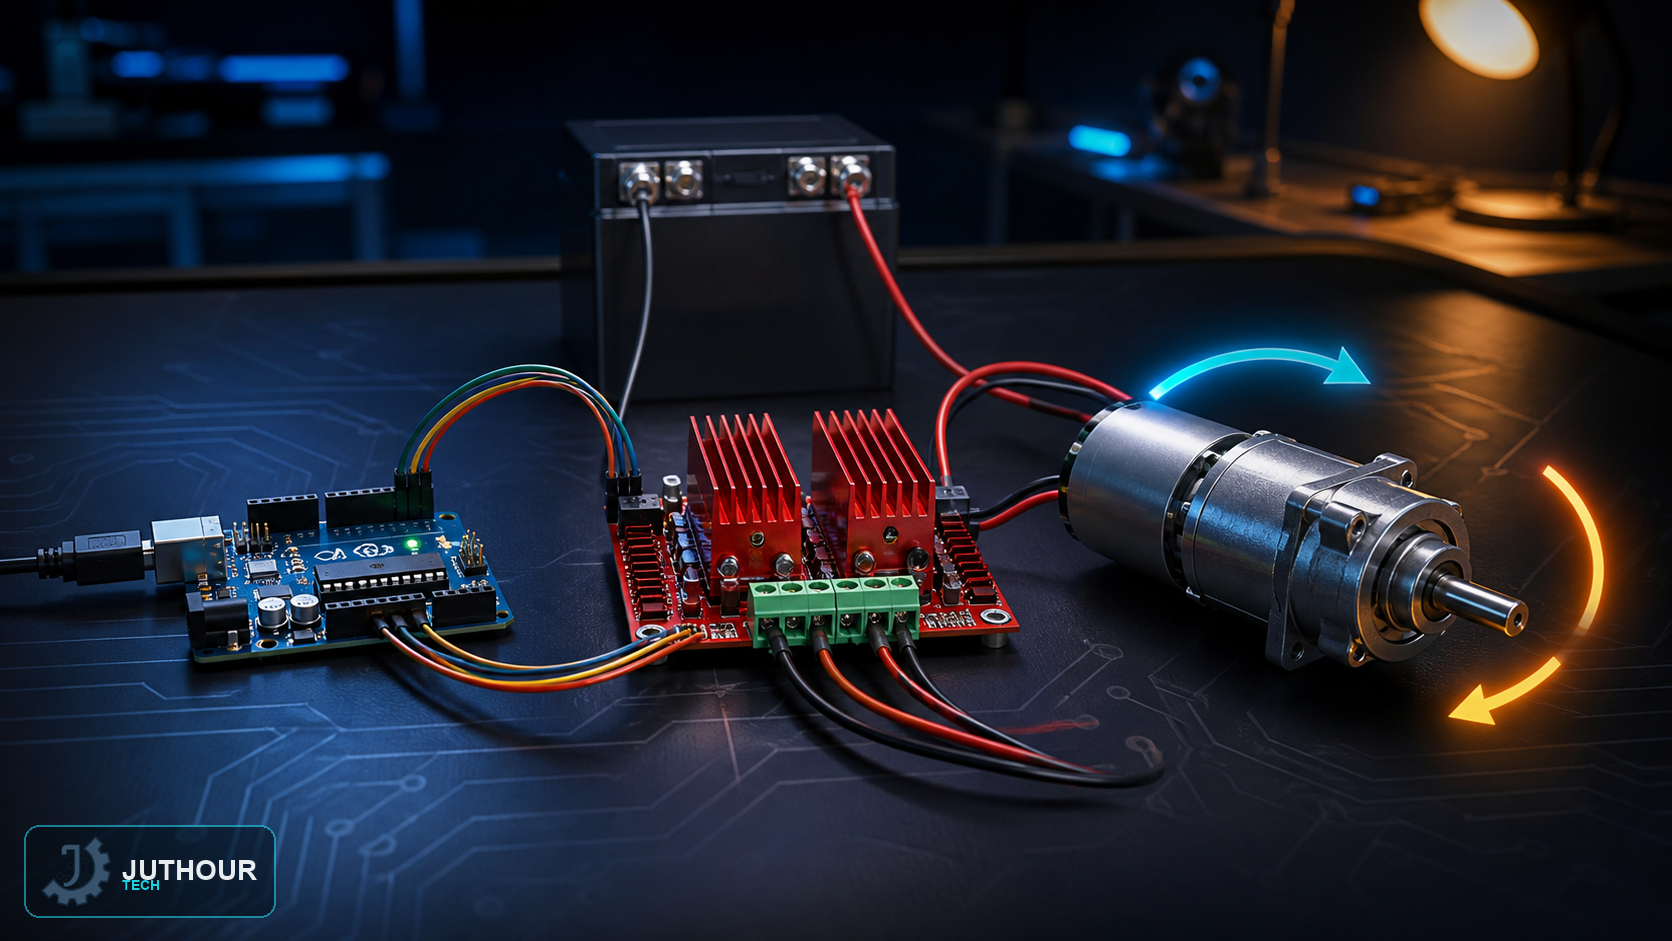
Wiring the L298N module to control a DC motor, with an important safety note on the 5V jumper when exceeding 12V.

Wiring the L298N module to control a bipolar stepper motor like the NEMA 17, and comparing it to the L293D chip.

Build a robot that automatically follows a drawn line using two IR reflectance sensors and an L298N motor driver module.