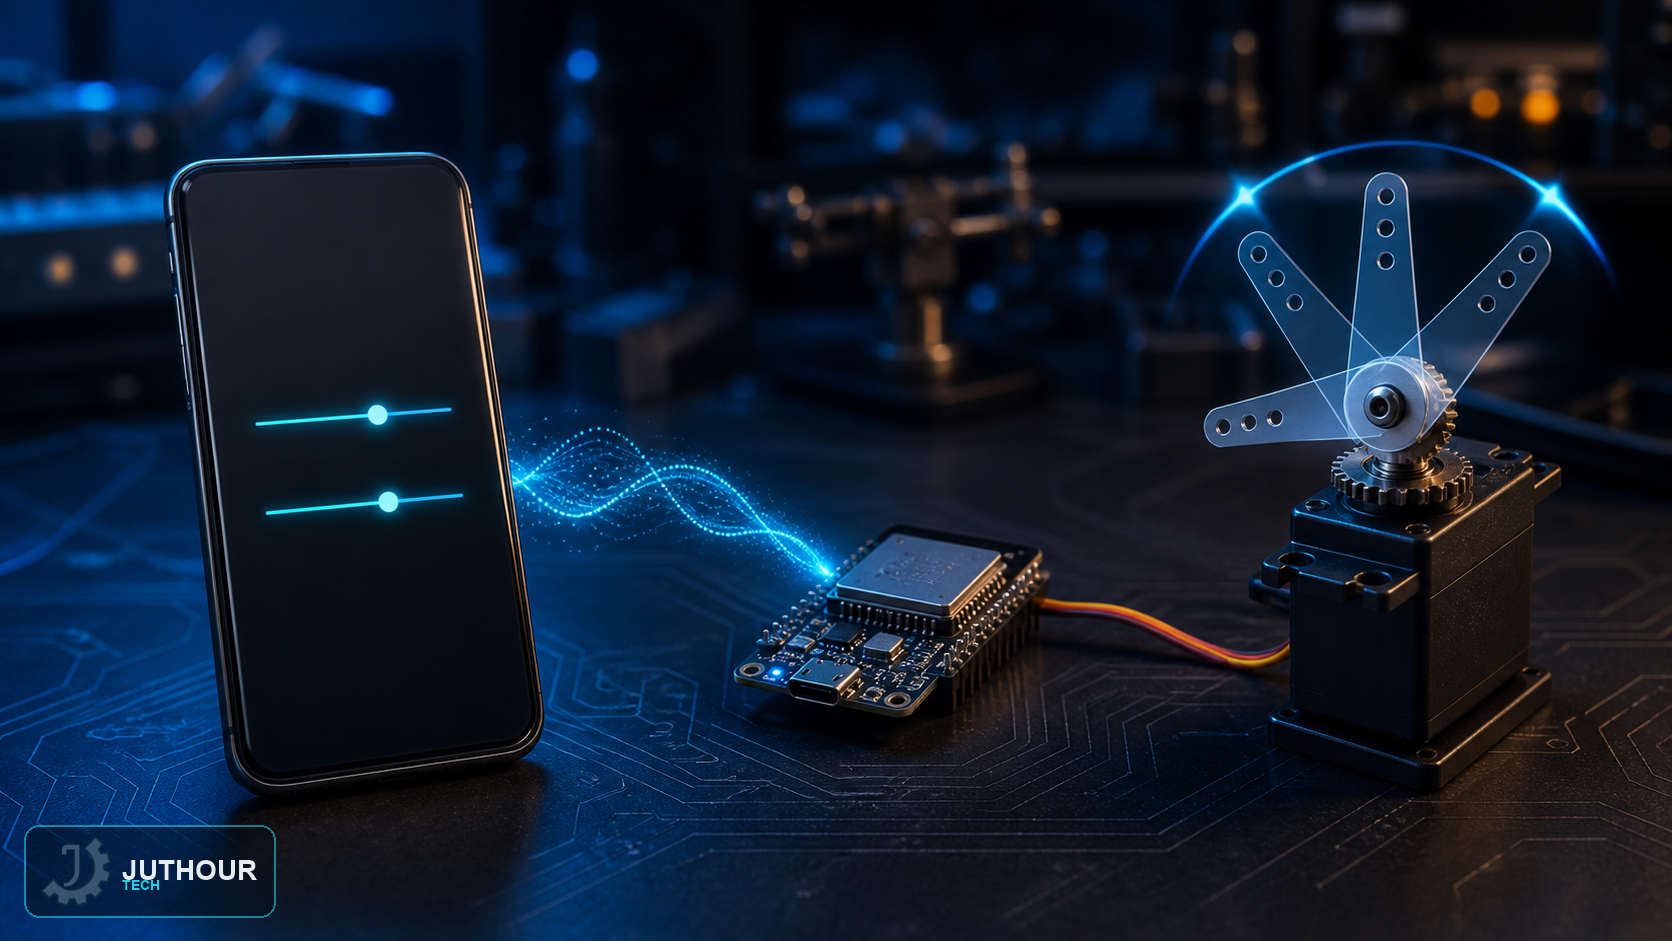
Build a local ESP32 servo interface with native fetch, debounced requests, server-side angle validation, safe limits, and remote-access guidance.
 JUTHOURTECH
Build a local ESP32 servo interface with native fetch, debounced requests, server-side angle validation, safe limits, and remote-access guidance.