
A guide to building a self-balancing robot using an MPU-6050 module and a PID algorithm to keep it balanced on two wheels.
 JUTHOURTECH
A guide to building a self-balancing robot using an MPU-6050 module and a PID algorithm to keep it balanced on two wheels.
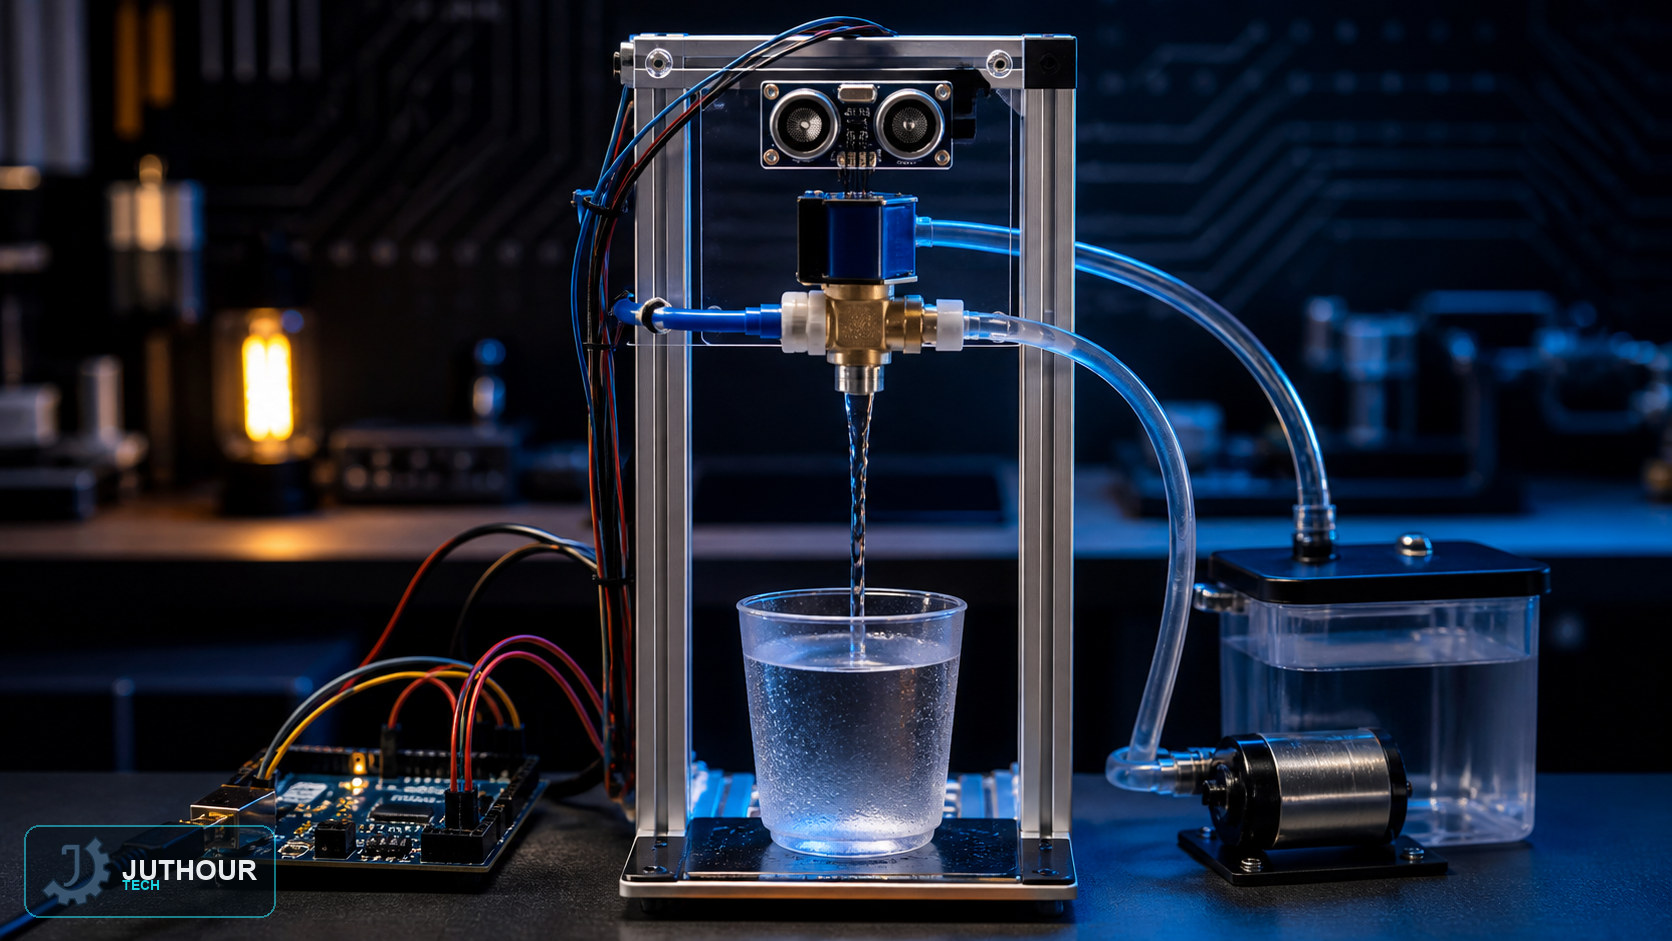
Build an automatic water dispenser that opens a solenoid valve when a container approaches, using a distance sensor and a MOSFET transistor.
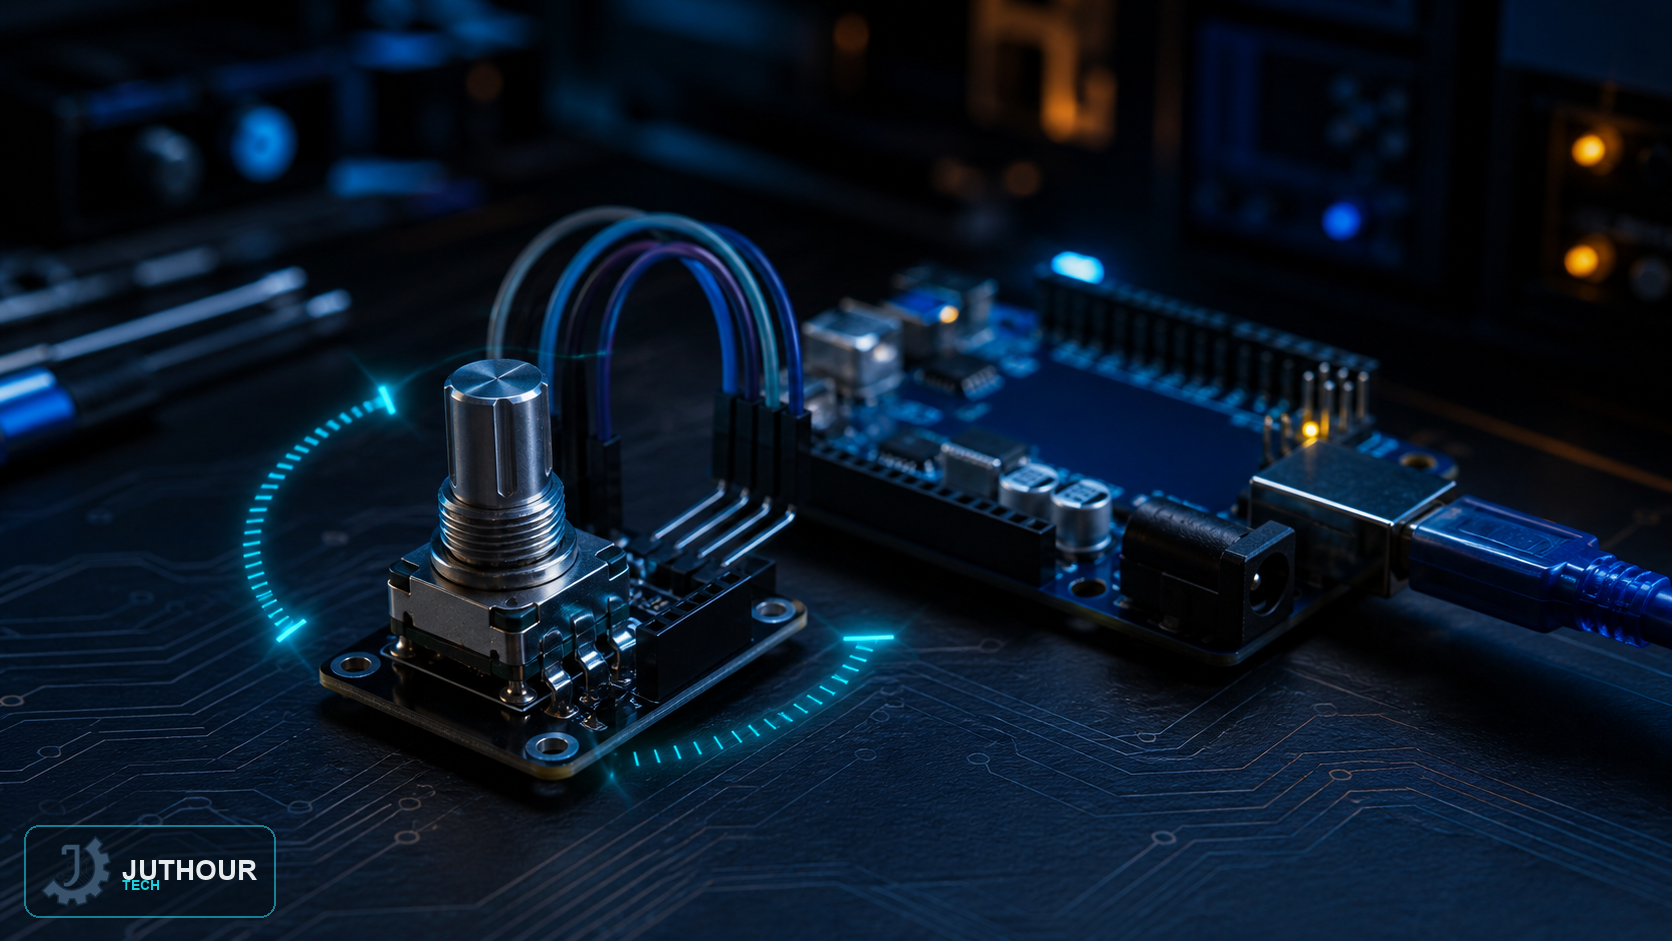
Wire a KY-040 rotary encoder to precisely determine rotation direction and step count, showing the value on an LCD.

Build a small piano with Arduino, eight buttons, and a buzzer, with the ability to record a played tune and replay it automatically with the same timing.