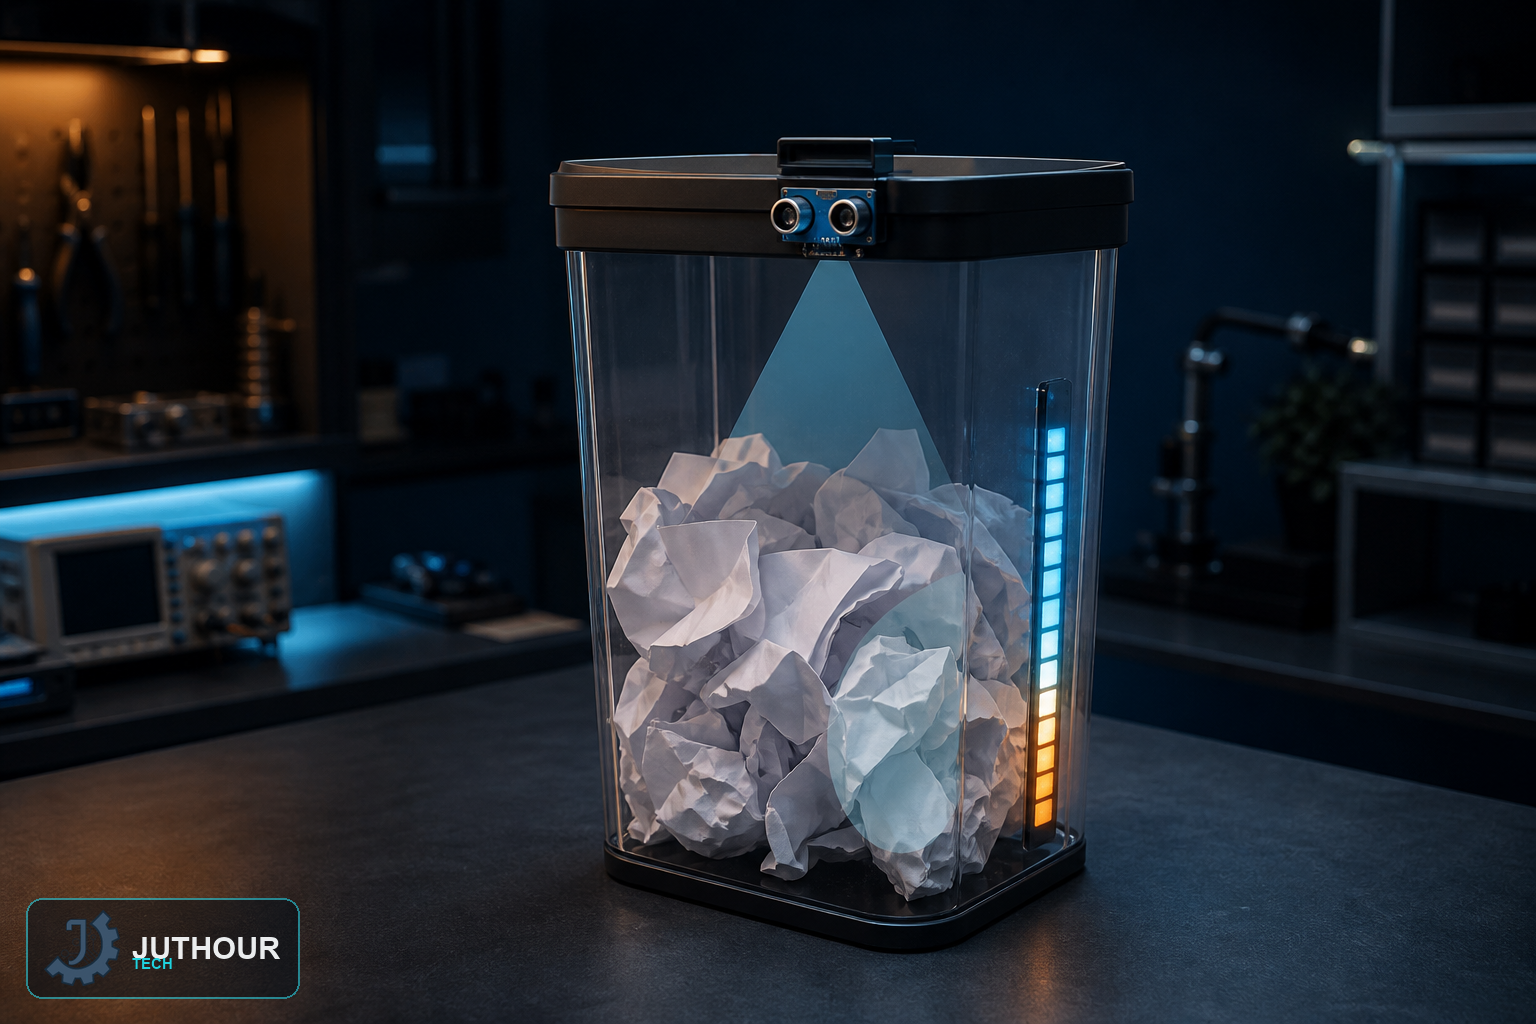
Estimate bin fill level with ultrasonic sensing while accounting for irregular waste surfaces, blind zones, contamination, and enclosure needs.
Prototype objective
This project focuses on measurement, state logic, feedback, and a low-voltage bench prototype that can be tested safely before any more advanced application is considered.
Suggested components
An Arduino Uno R3, an HC-SR04 ultrasonic sensor, a 16x2 I2C LCD, a yellow LED, a white LED, an active buzzer, a breadboard, and jumper wires.
Wiring and implementation
The HC-SR04's Trig and Echo pins connect to pins 12 and 11, the yellow LED connects to pin 10, the white LED to pin 9, the buzzer to pin 8, and the LCD uses standard I2C wiring.
Use a regulated supply and common ground, drive loads through suitable interface stages, add flyback protection for inductive loads, and condition logic levels where required.
Test plan
Test uneven and soft contents, lid movement, condensation, contamination, and minimum range; add filtering and a serviceable sensor enclosure.
Use limitations
A single overhead distance reading can be blocked or distorted by the waste shape. Do not use the prototype for hazardous, pressurized, hot, or chemically aggressive waste streams.
Next step
Document the schematic, library versions, measurements, and failure cases before extending the prototype, and consult qualified specialists and applicable standards whenever safety, health, vehicles, or industrial equipment are involved.
اترك تعليقا