
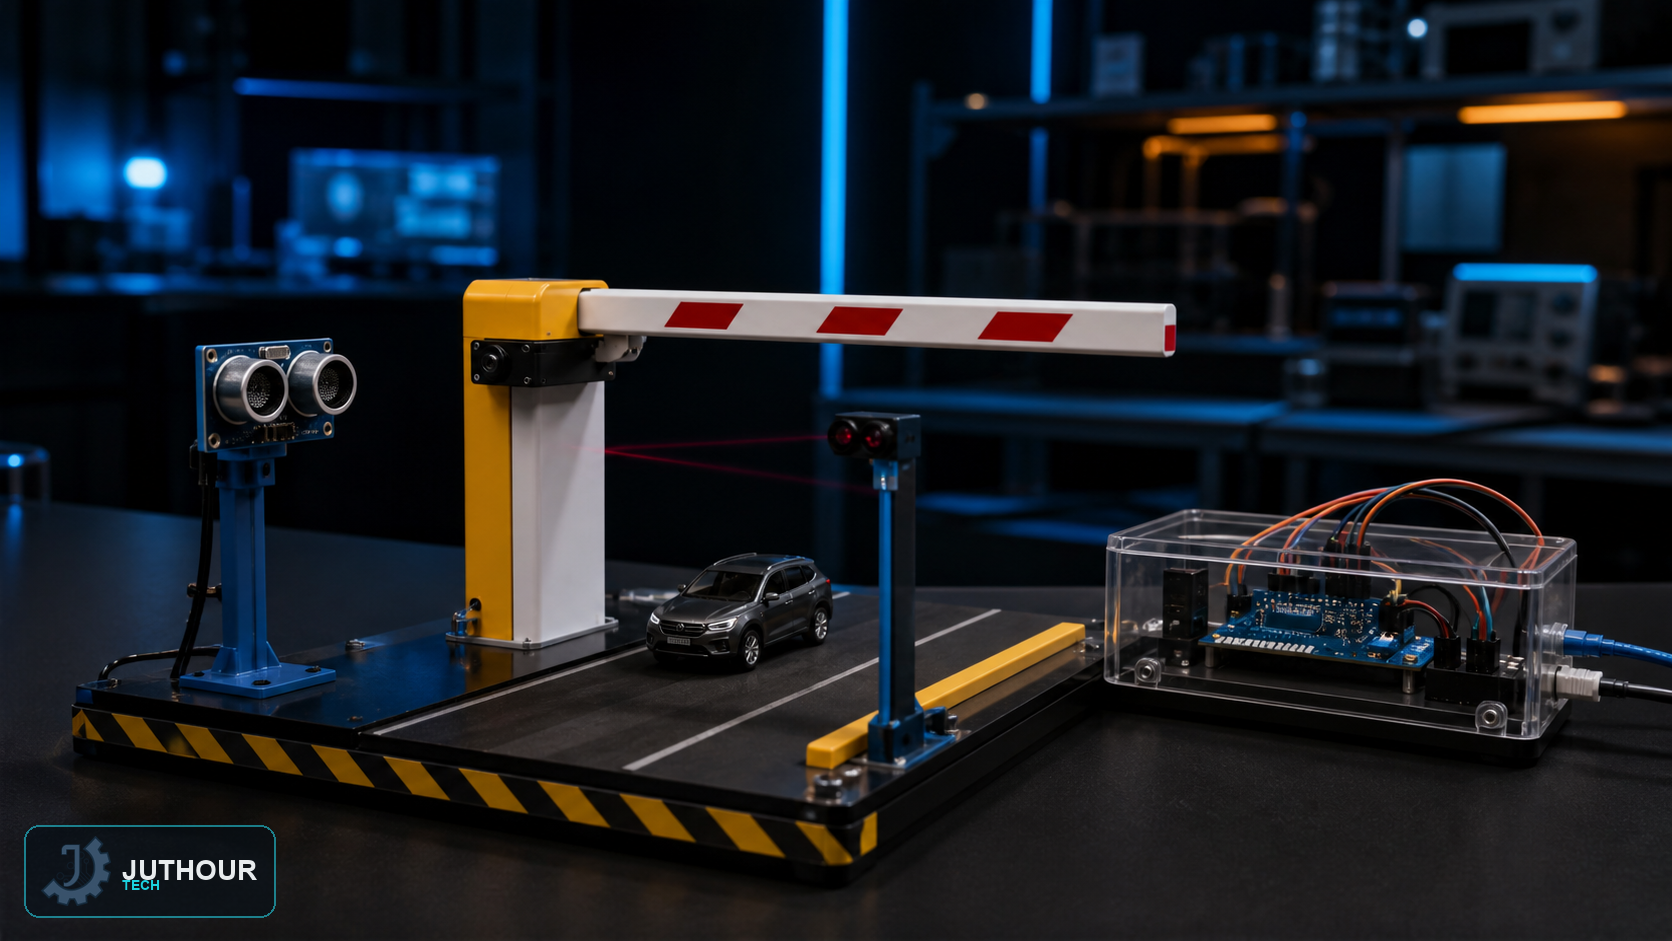
The prototype demonstrates vehicle detection and servo motion, but one range sensor and a fixed delay are not enough for a safe real barrier.
Prototype logic
An approach sensor may request opening, while an independent passage sensor confirms that the vehicle has cleared before closing. Use a state machine instead of long delays, with timeouts and a manual fault exit.
Safety devices
Add a photoelectric obstruction beam or safety edge, limit force and speed, and provide manual release and a safe state for power or sensor failure.
Power
Use a suitable servo supply with shared ground and keep motor current out of the controller rail. This is an educational model, not a certified barrier controller.
Engineering review: verify the library version, module operating voltage, and the actual board pinout before wiring; visually similar breakout boards can differ.
اترك تعليقا